Gripping with Niklas Hagemann
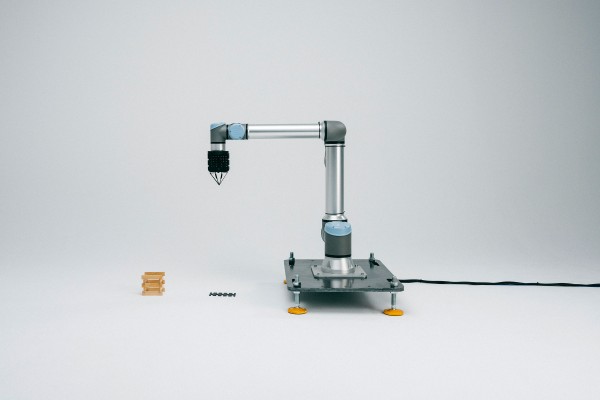
Gripping, proposed by the Swiss designer, engineer and MIT researcher Niklas Hagemann and developed with the research team, AATB (Andrea Anner and Thibault Brevet), Alain Bellet and Martin Hertig, is one of the six experiments of A Third Hand – Creative Applications for Robotics, a research project at ECAL/University of Art and Design Lausanne, Switzerland.
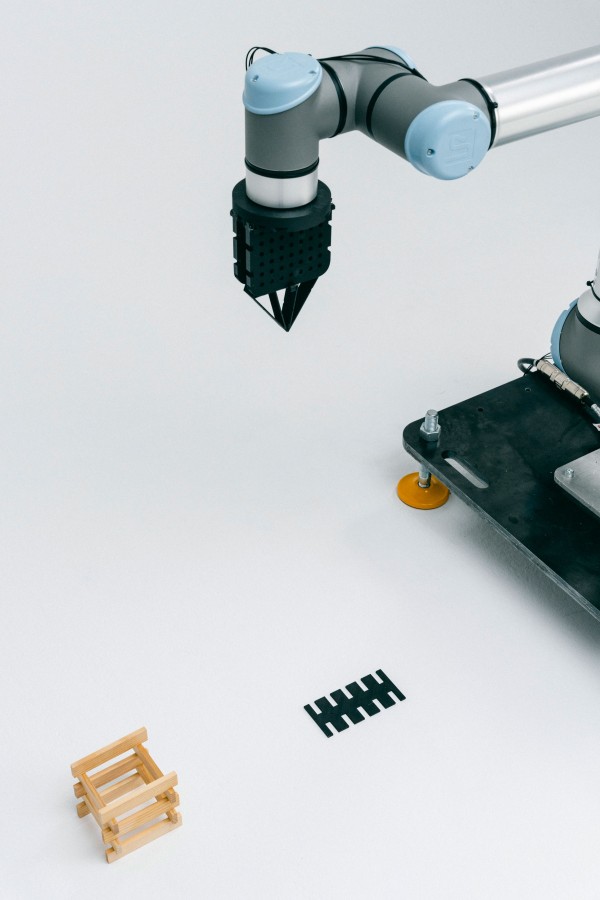
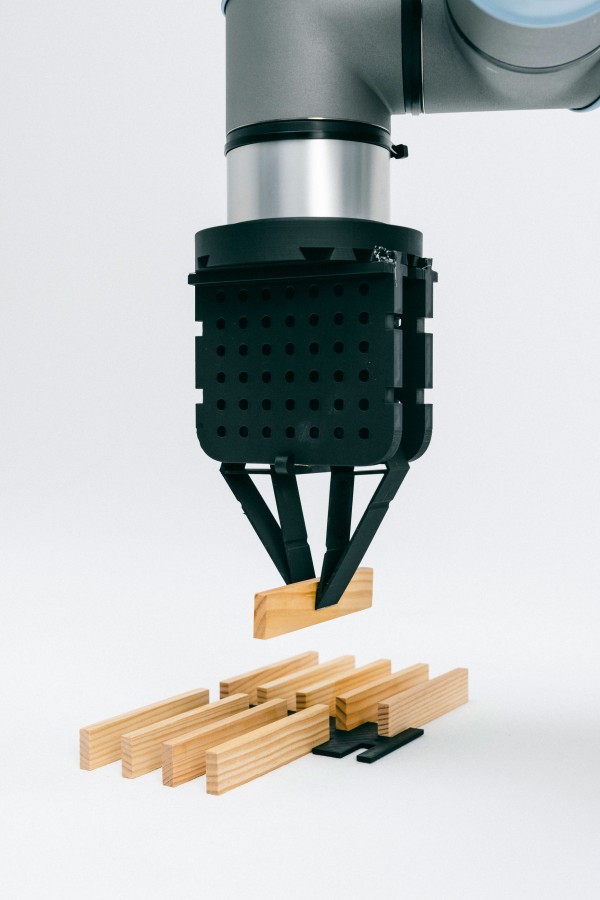
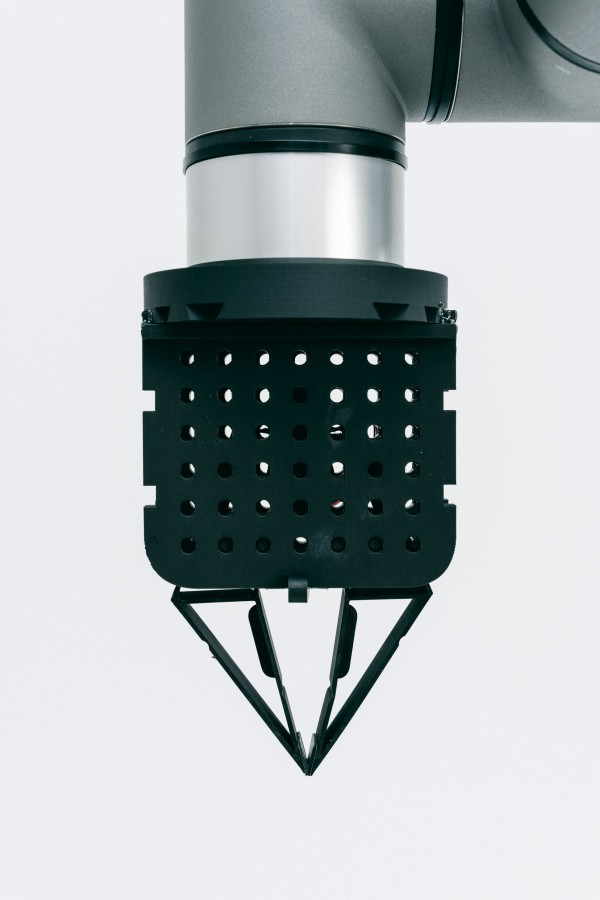
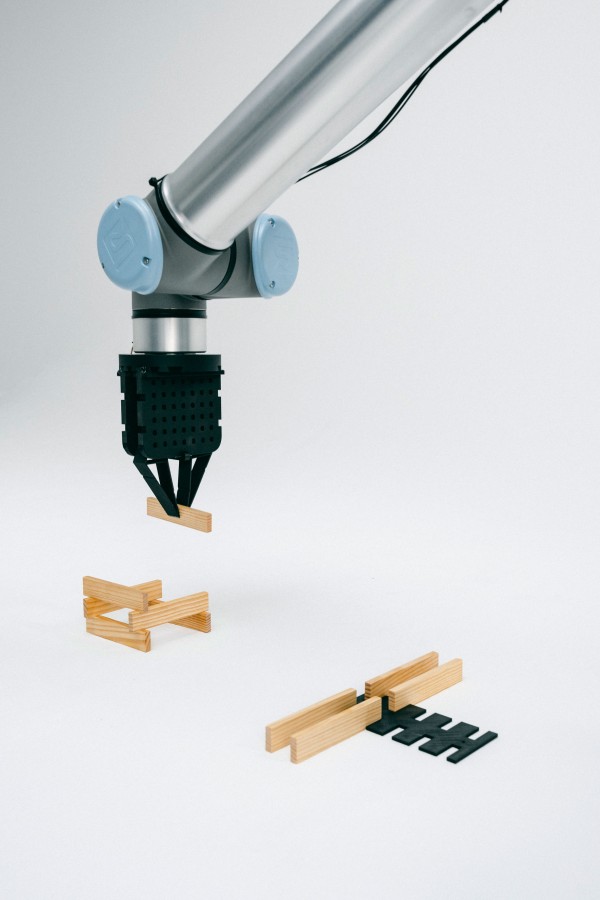
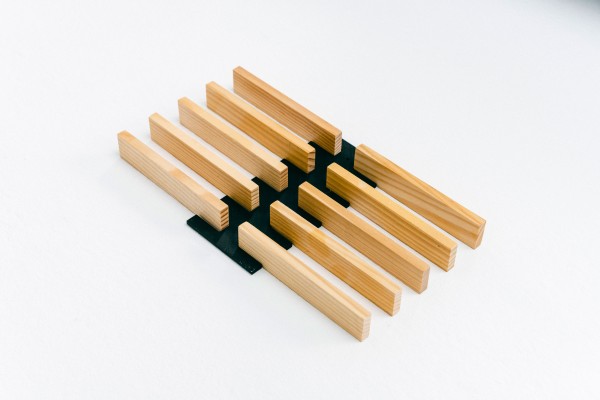
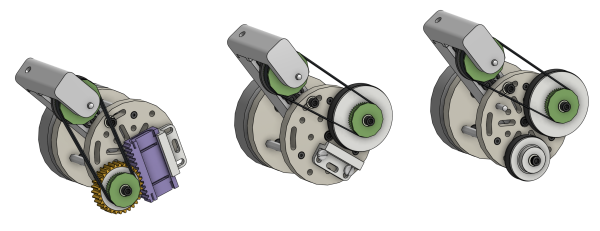
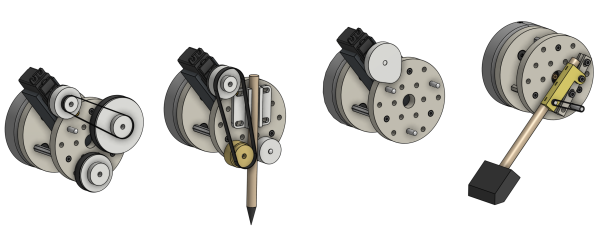
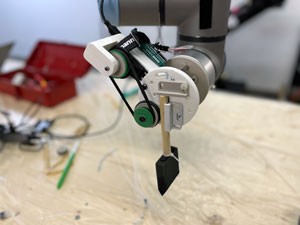
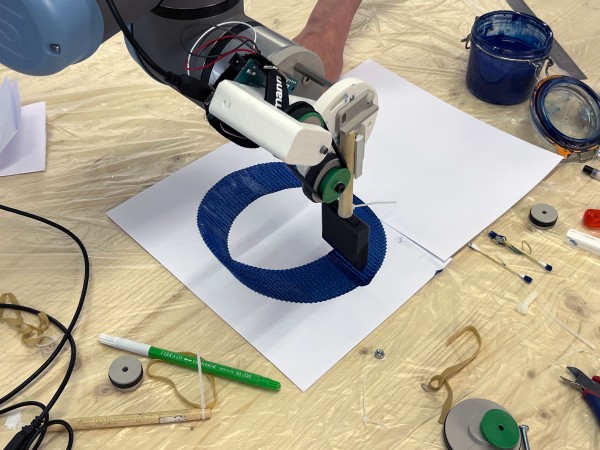
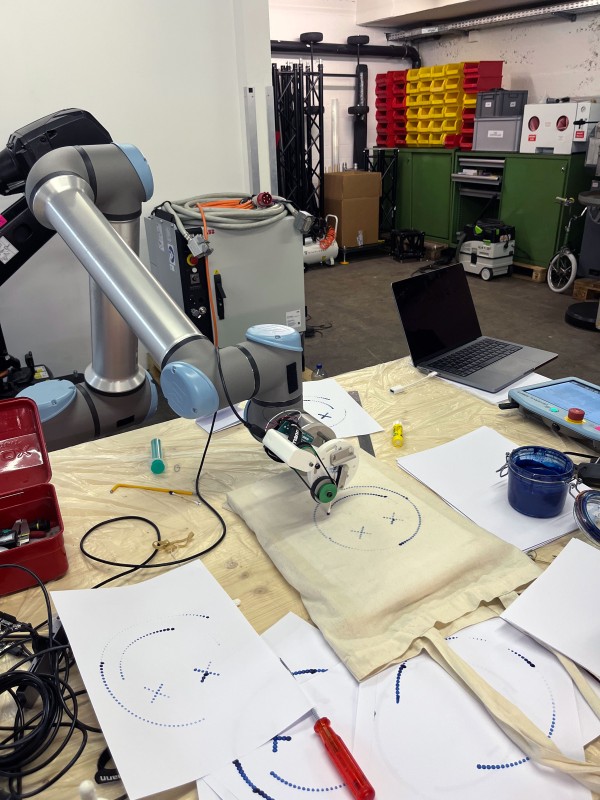
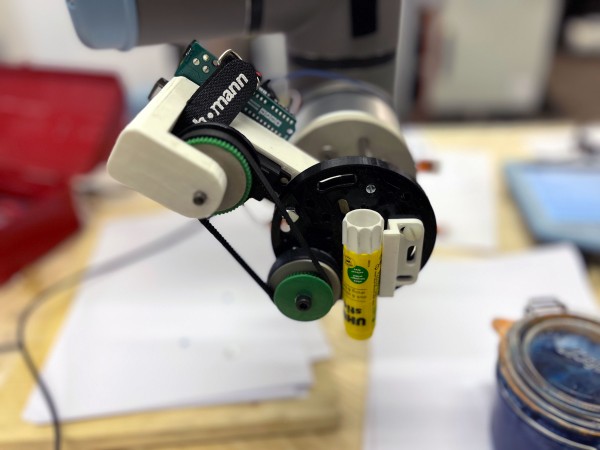
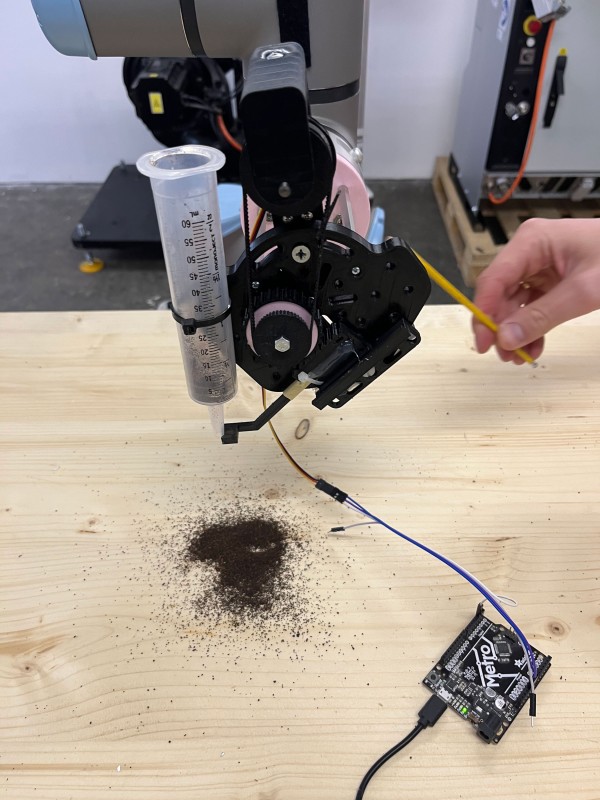
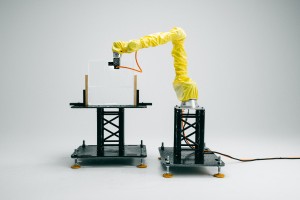
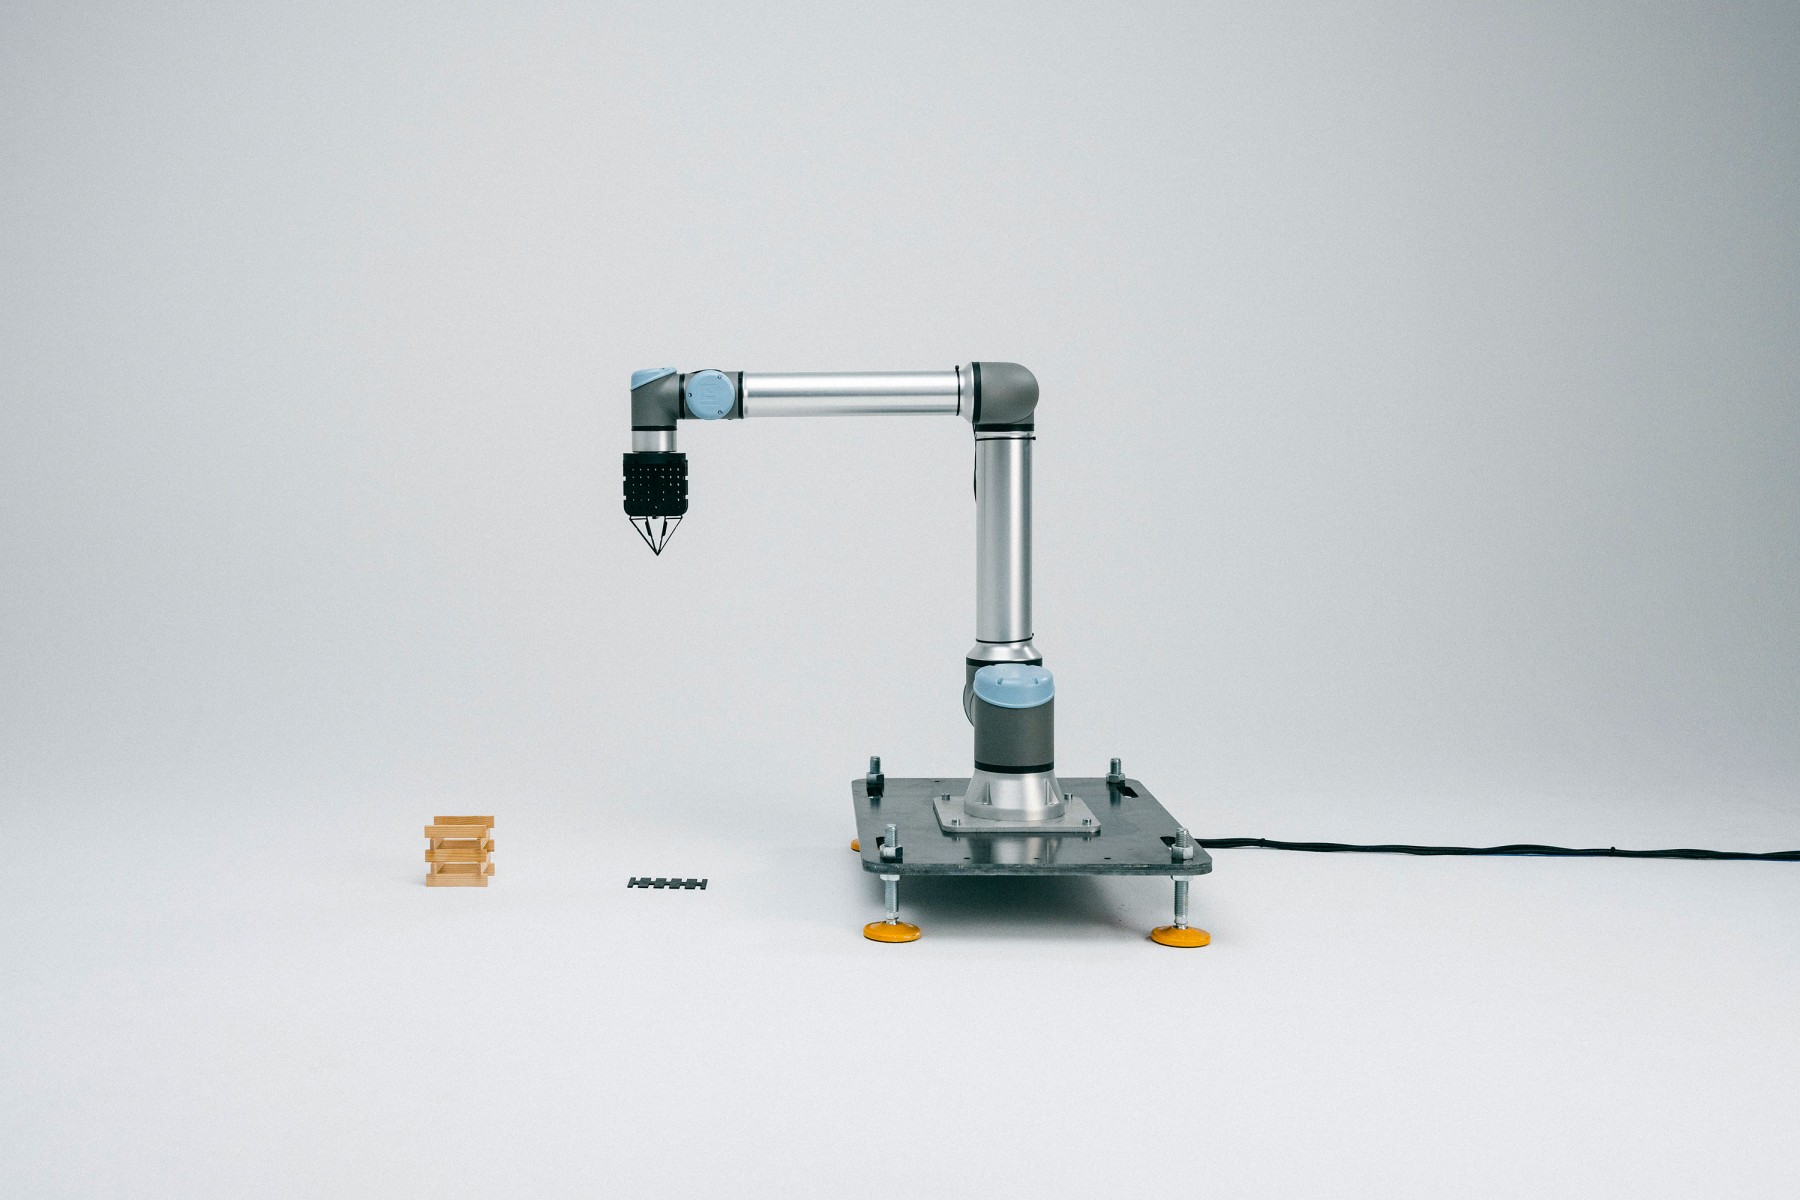
Working between the AATB workshop in Zurich and Boston, Hagemann developed a modular, hackable toolkit for robot end-effectors, “something somewhere between LEGO and an optical test-bench”. Its final piece is a 3D-printable gripper whose flexible sectors deform under pressure, driven by a servo and an Arduino wired to the UR10’s inputs, and able to stack Kapla towers from automatically generated URScript.